Hi! I’m Zhen Tan (谭臻). I am currently an Algorithm Researcher at XGRIDS, working on the company’s 4D Reconstruction direction (4D Gaussian Splatting / World Model), and concurrently a Postdoctoral Researcher at the Harbin Institute of Technology, Shenzhen (HITSZ), pursuing industry-academia collaborative research. I received my Ph.D. from the National University of Defense Technology (NUDT), supervised by Prof. Dewen Hu (CAS Academician) and Assoc. Prof. Xieyuanli Chen. Prior to this, I obtained my Master’s degree from the Technical University of Munich (TUM), guided by Prof. Yusheng Xu, and my Bachelor’s degree from Wuhan University (WHU).
My research spans 3D/4D Vision and Spatial Intelligence, covering radiance field reconstruction (NeRF/3DGS), visual SLAM, feed-forward generalizable reconstruction, geometric surface reconstruction, dynamic scene 4D reconstruction, and embodied perception — forming a complete pipeline from scene representation and reconstruction to perception and decision-making. My work is published at top-tier venues including CVPR, ICRA, IROS, and RA-L.
I value the intersection of academic research and industrial deployment, with hands-on experience spanning autonomous driving sensor fusion (LiangDao Intelligence), 3D reconstruction algorithms (CVLife, 4DV.ai), embodied intelligence (XPENG Motors), and 4D reconstruction / world models (XGRIDS).
🔥 News
- 2026.08: 🚀🚀 Joined XGRIDS as an Algorithm Researcher, and started my postdoctoral research at HITSZ!
- 2026.01: 🎉🎉 One paper is accepted to CVPR 2026 (TAPFormer)!
- 2025.12: 🎉🎉 One Paper is accepted to RA-L 2025!
- 2025.10: 🏆🏆 We won the Champion of the IROS 2025 EvSLAM Challenge!
- 2025.06: 🎉🎉 One Paper is accepted to IROS 2025!
- 2025.01: 🎉🎉 One Paper is accepted to ICRA 2025!
- 2024.06: 🎉🎉 One Paper is accepted to IROS 2024!
📝 Publications
* denotes equal contribution.
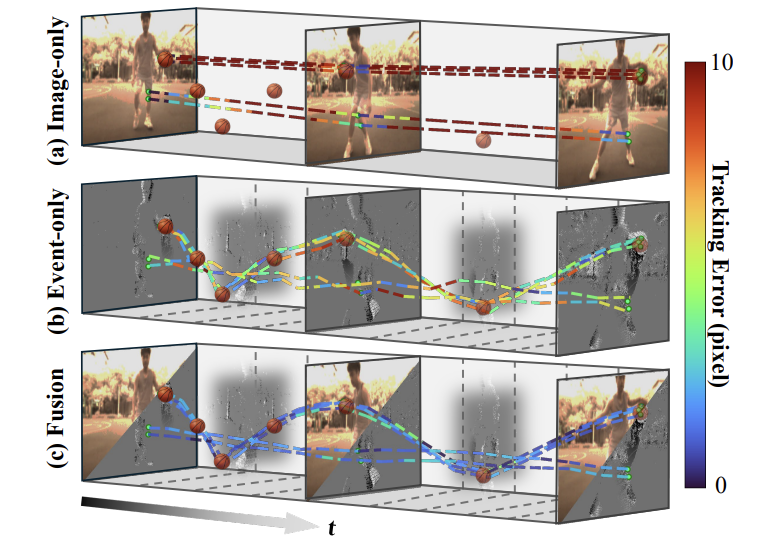
TAPFormer: Robust Arbitrary Point Tracking via Transient Asynchronous Fusion of Frames and Events
J. Liu, Zhen Tan, J. Zhang, Y. Zhou, H. Shen, Xieyuanli Chen, Dewen Hu
- Proposes a transient asynchronous fusion mechanism to align the spatiotemporal information of frames and event cameras.
- Achieves robust, high-frame-rate arbitrary point tracking under highly dynamic scenes, and explores using tracking priors for dynamic 4D reconstruction.
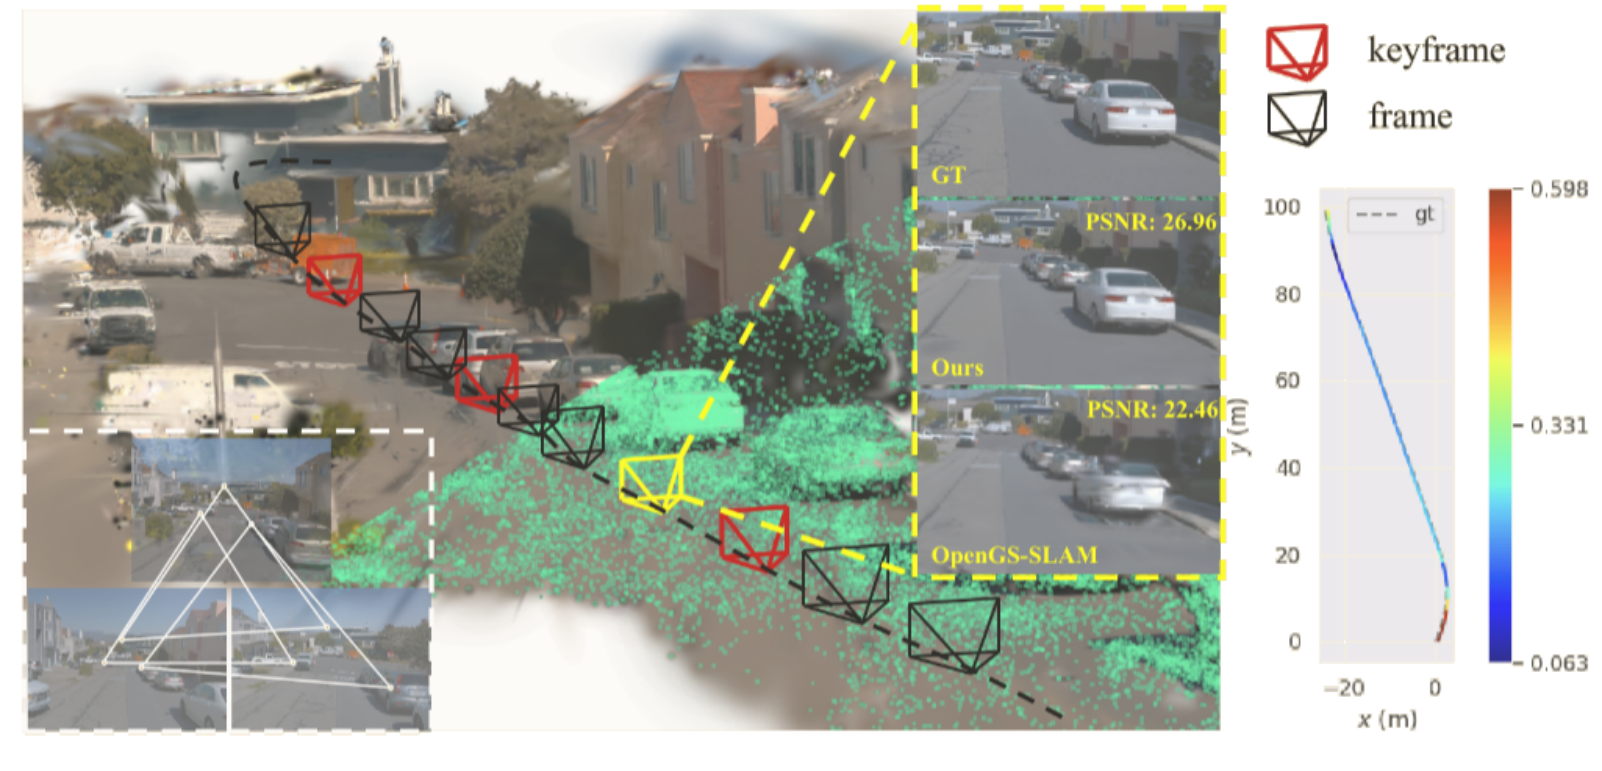
TVG-SLAM: Robust Gaussian Splatting SLAM with Tri-view Geometric Constraints
Zhen Tan, Xieyuanli Chen, L. Feng, Y. Ge, S. Zhi, J. Liu, Dewen Hu
- Proposed a tri-view geometric constraint to address the instability of 3D Gaussian Splatting in texture-less or repetitive regions.
- Achieved tightly-coupled optimization of camera tracking and high-fidelity mapping, ensuring robustness in challenging outdoor environments.
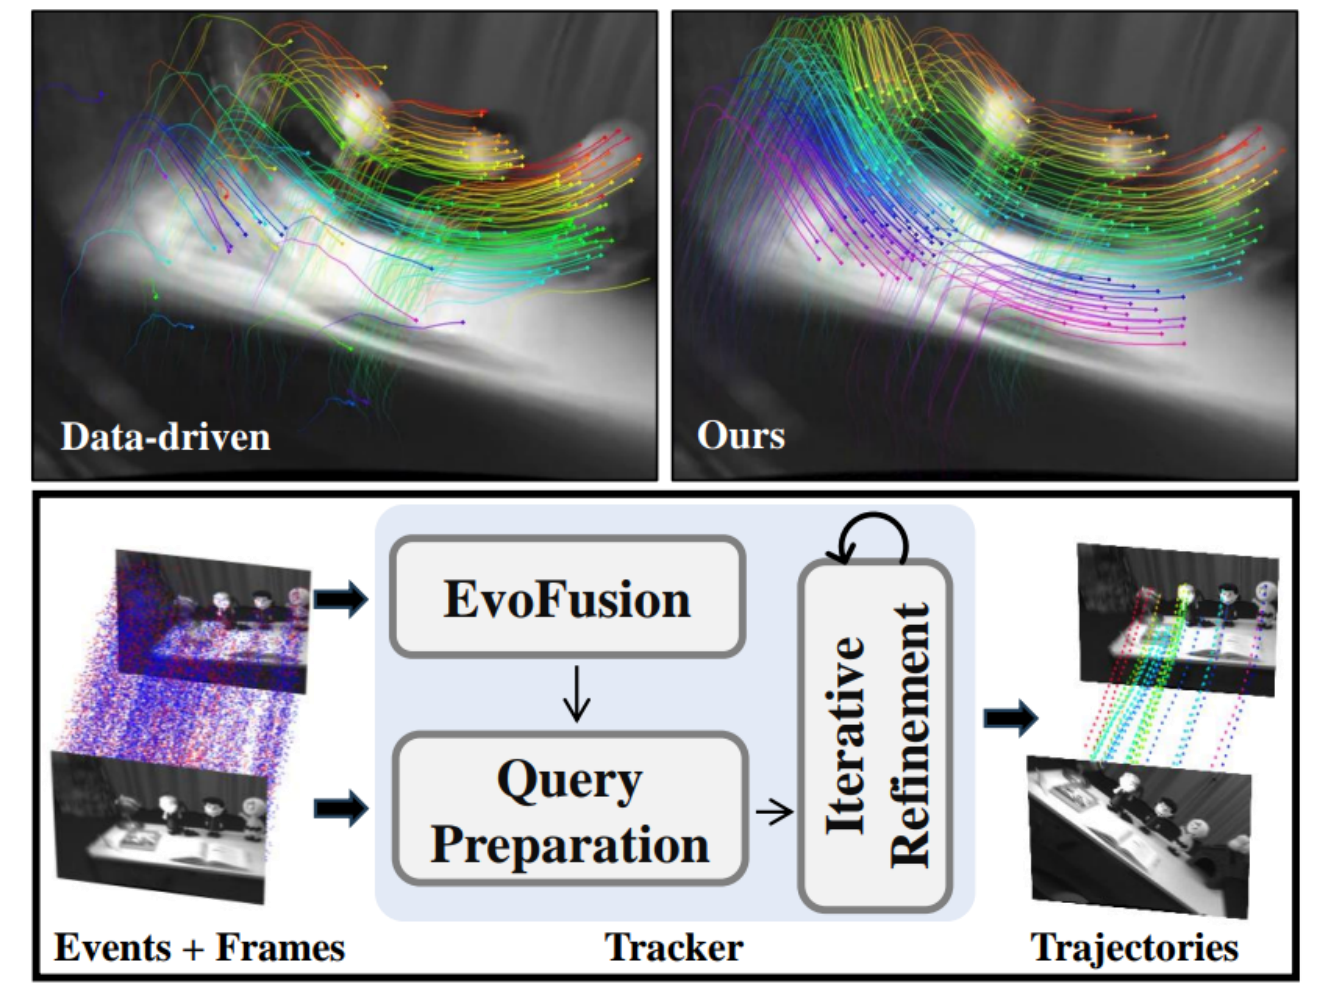
Tracking Any Point with Frame-Event Fusion Network at High Frame Rate
J. Liu, B. Wang, Zhen Tan, J. Zhang, H. Shen, Dewen Hu
- Explored multi-modal fusion of RGB frames and Event cameras for robust point tracking in high-dynamic scenarios.
- Leveraged the high temporal resolution of event data to maintain tracking stability under rapid motion, providing a reliable perception front-end for dynamic robotic tasks.
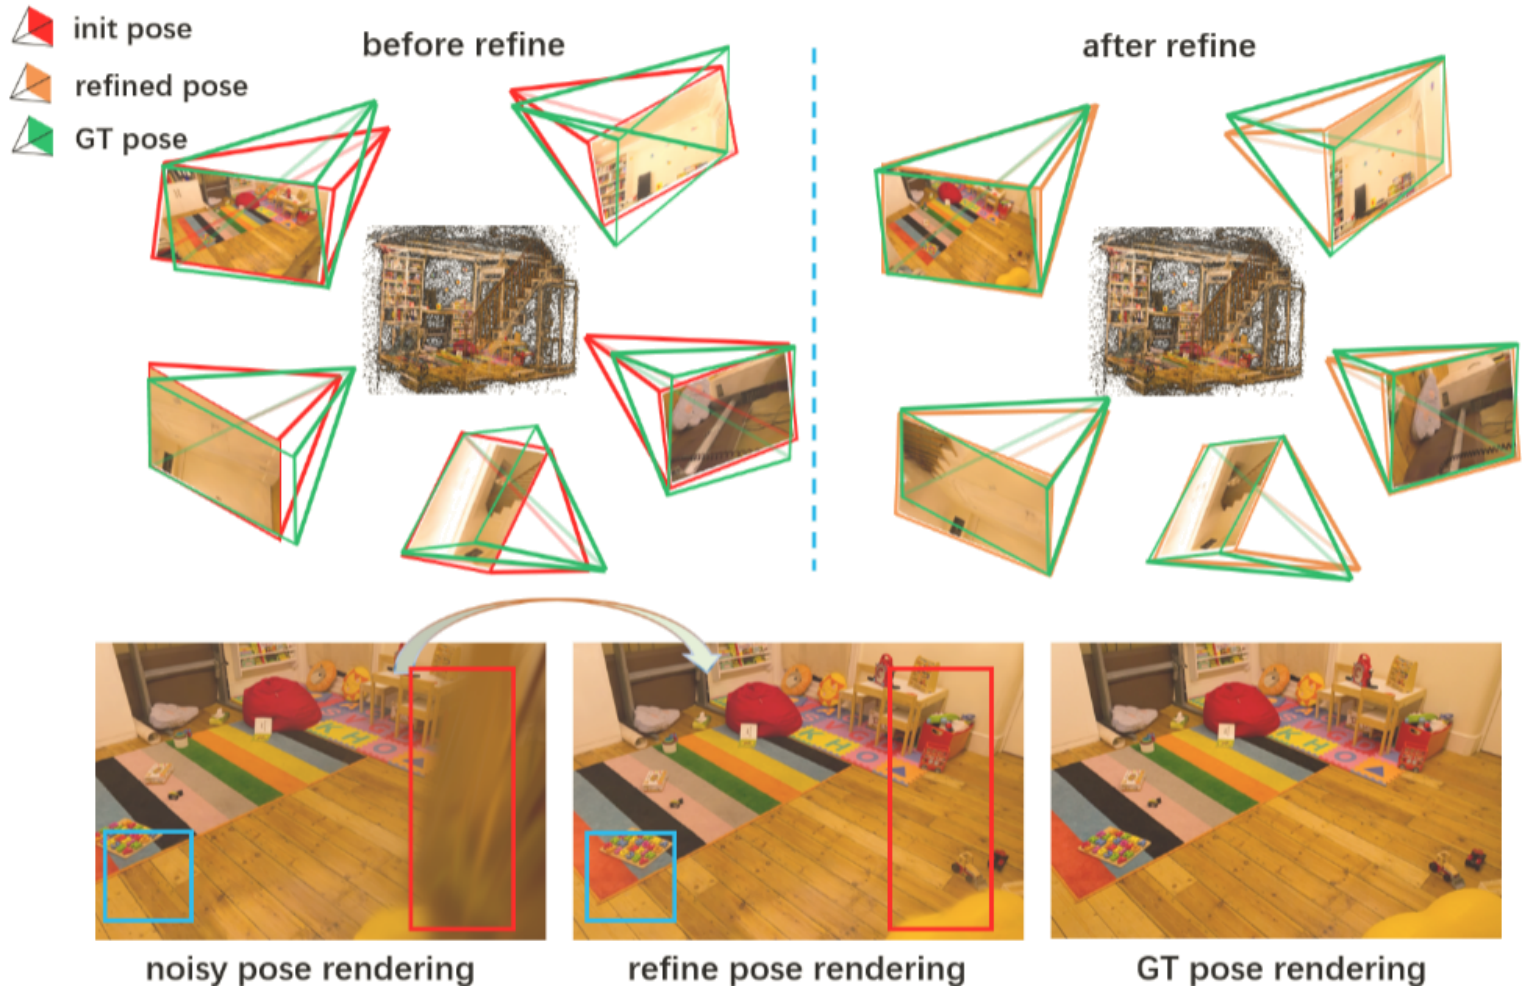
HGSLoc: 3DGS-based Heuristic Camera Pose Refinement
Z. Niu, Zhen Tan, J. Zhang, X. Yang, Dewen Hu
- Developed a heuristic camera pose refinement framework leveraging 3D Gaussian Splatting as a dense map prior.
- Significantly improved visual relocalization accuracy by aligning query images with rendered views, facilitating long-term autonomy in persistent environments.
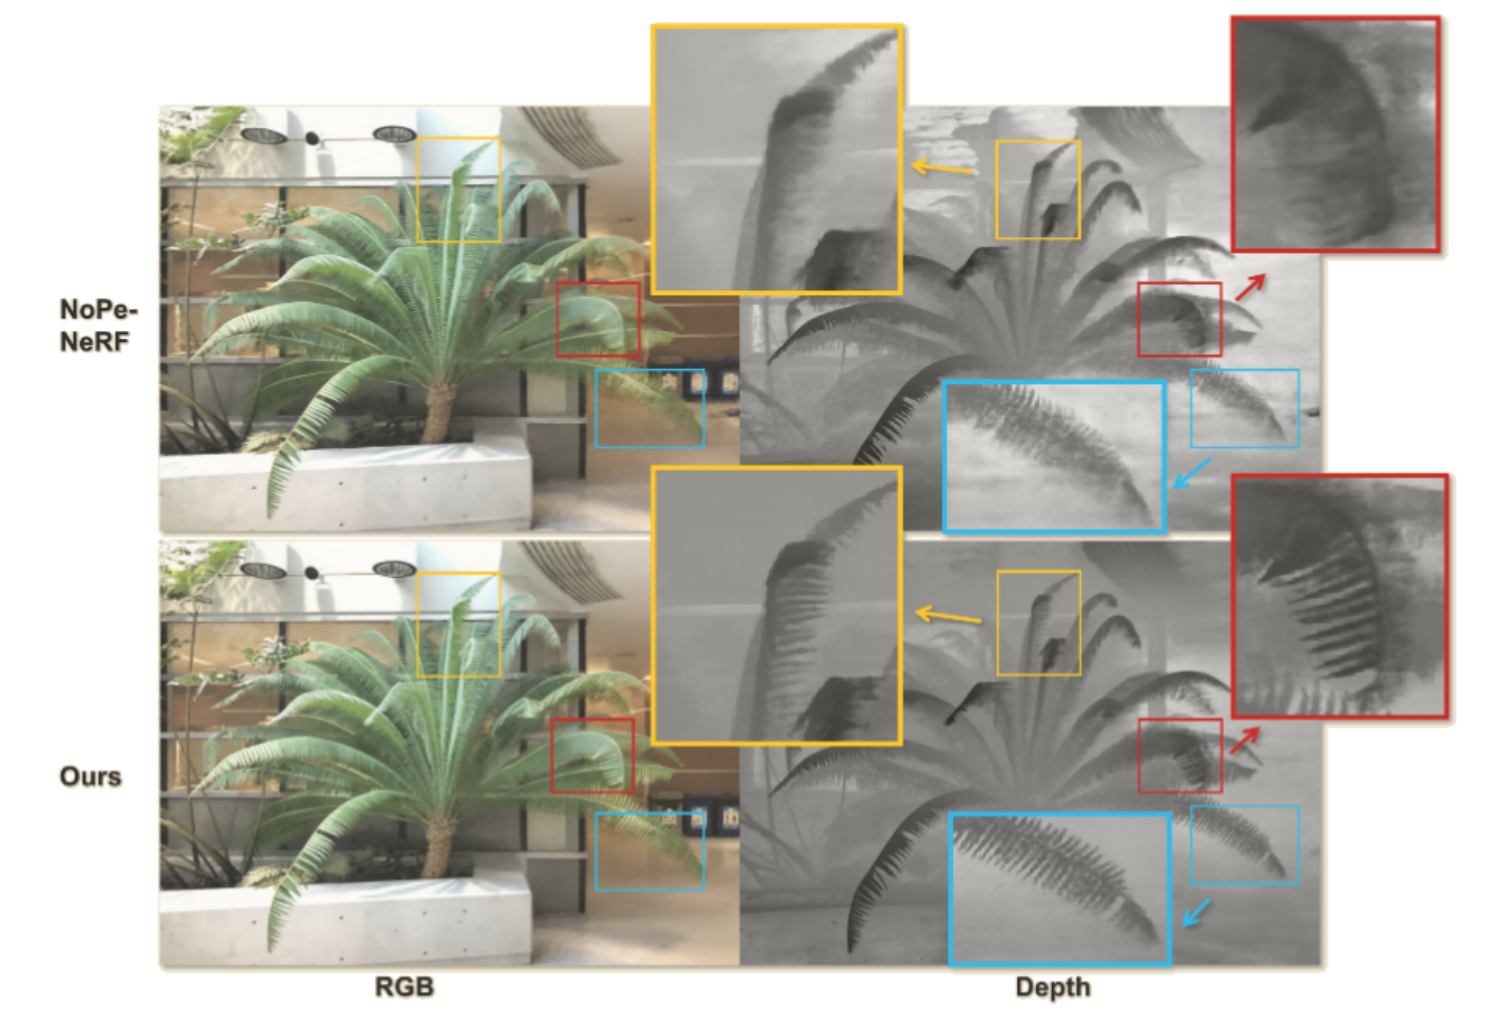
TD-NeRF: Novel Truncated Depth Prior for Joint Camera Pose and Neural Radiance Field Optimization
Zhen Tan, Z. Zhou, Y. Ge, Z. Wang, Xieyuanli Chen, Dewen Hu
- Address the dependency of NeRF on pre-computed COLMAP poses by introducing a truncated depth prior.
- Enabled joint optimization of neural radiance fields and camera poses, allowing for high-quality reconstruction without accurate initial pose priors.
🧑💻 Experience
- 2026.08 - Present, Algorithm Researcher, XGRIDS. Contributing to the company’s 4D Reconstruction direction (4DGS / World Model): technical roadmap planning, core algorithm R&D, and patent/paper pipeline.
- 2026.08 - Present, Postdoctoral Researcher, Harbin Institute of Technology, Shenzhen (HITSZ). Researching dynamic scene 4D reconstruction and world models, in industry-academia collaboration with XGRIDS.
- 2026.05 - 2026.07, Algorithm Research Intern, XGRIDS (4D Reconstruction Team). Investigated 4DGS and World Model techniques and built early algorithm prototypes for dynamic scene 4D reconstruction.
- 2026.01 - 2026.05, Embodied AI Algorithm Intern, XPENG Motors (General AI Center). Worked on VLA (Vision-Language-Action) and World Model research for embodied intelligence, focusing on the “cerebellum” module of a brain-cerebellum robot architecture.
- 2025.07 - 2025.09, Algorithm Intern, 4DV.ai (3D Vision Algorithm Team). Researched monocular 4D Gaussian Splatting on iPhone-captured monocular RGB-D data, fusing temporal point tracking to reconstruct high-fidelity dynamic scenes.
- 2024.04 - 2024.06, Algorithm Intern, CVLife (Reconstruction Algorithm Team). Accelerated and deployed a differentiable Gaussian Splatting renderer (40%+ speedup); researched the full pipeline of 3DGS-to-mesh conversion to improve geometric reconstruction quality.
- 2021.01 - 2022.02, Sensor Fusion Algorithm Engineer, LiangDao Intelligence (European R&D Center). Led development of LiDAR-camera post-fusion algorithms for highway autonomous driving and roadside perception fusion.
⚖ Academic Service
Conference Reviewer: ICRA, IROS
Journal Reviewer: IEEE Transactions on Visualization and Computer Graphics (TVCG), ACM Transactions on Multimedia Computing, Communications, and Applications (TOMM), IEEE Transactions on Circuits and Systems for Video Technology (TCSVT), IEEE Robotics and Automation Letters (RA-L)
🎖 Honors and Awards
- 2025, IROS 2025 EvSLAM Challenge, Champion.
- 2025, Second-class Scholarship for Outstanding Students, NUDT.
- 2022, Freshman Scholarship of NUDT, First Prize.
- 2021, Munich Innovation Challenge (Tech Innovation Award), 1st Place (Key Team Member).
- 2020/21, German Chinese Football Championship, Champion.
- 2018, “Outstanding Student” Award, Wuhan University.
- 2017, Remote Sensing Star in Wuhan University, Top 10 Students.
- 2017, Scholarship (Grade B), Wuhan University.
- 2016, Hubei Province Collegiate 11-a-side Football League, Champion (Starting Midfielder).
- 2016, “Outstanding Student Scholarship”, Wuhan University.
- 2015, Advanced Individual, Wuhan University Summer Social Practice; Volunteer in the “Rainbow Action” for left-behind children, Hubei Province.
📖 Educations
- 2022.09 - Present, Ph.D. in Control Science and Engineering, National University of Defense Technology (NUDT).
- 2018.09 - 2022.01, M.Sc. in Geodesy and Geoinformation, Technical University of Munich (TUM) (QS Top 30).
- 2014.09 - 2018.06, B.Eng. in Photogrammetry and Remote Sensing, Wuhan University (WHU).
💬 Hobbies
- Sports: Football (University Team Captain), Skiing, Basketball, Taekwondo, Martial Arts, Dancing.
- Arts: Movies.
- Travel: Exploring different cultures.